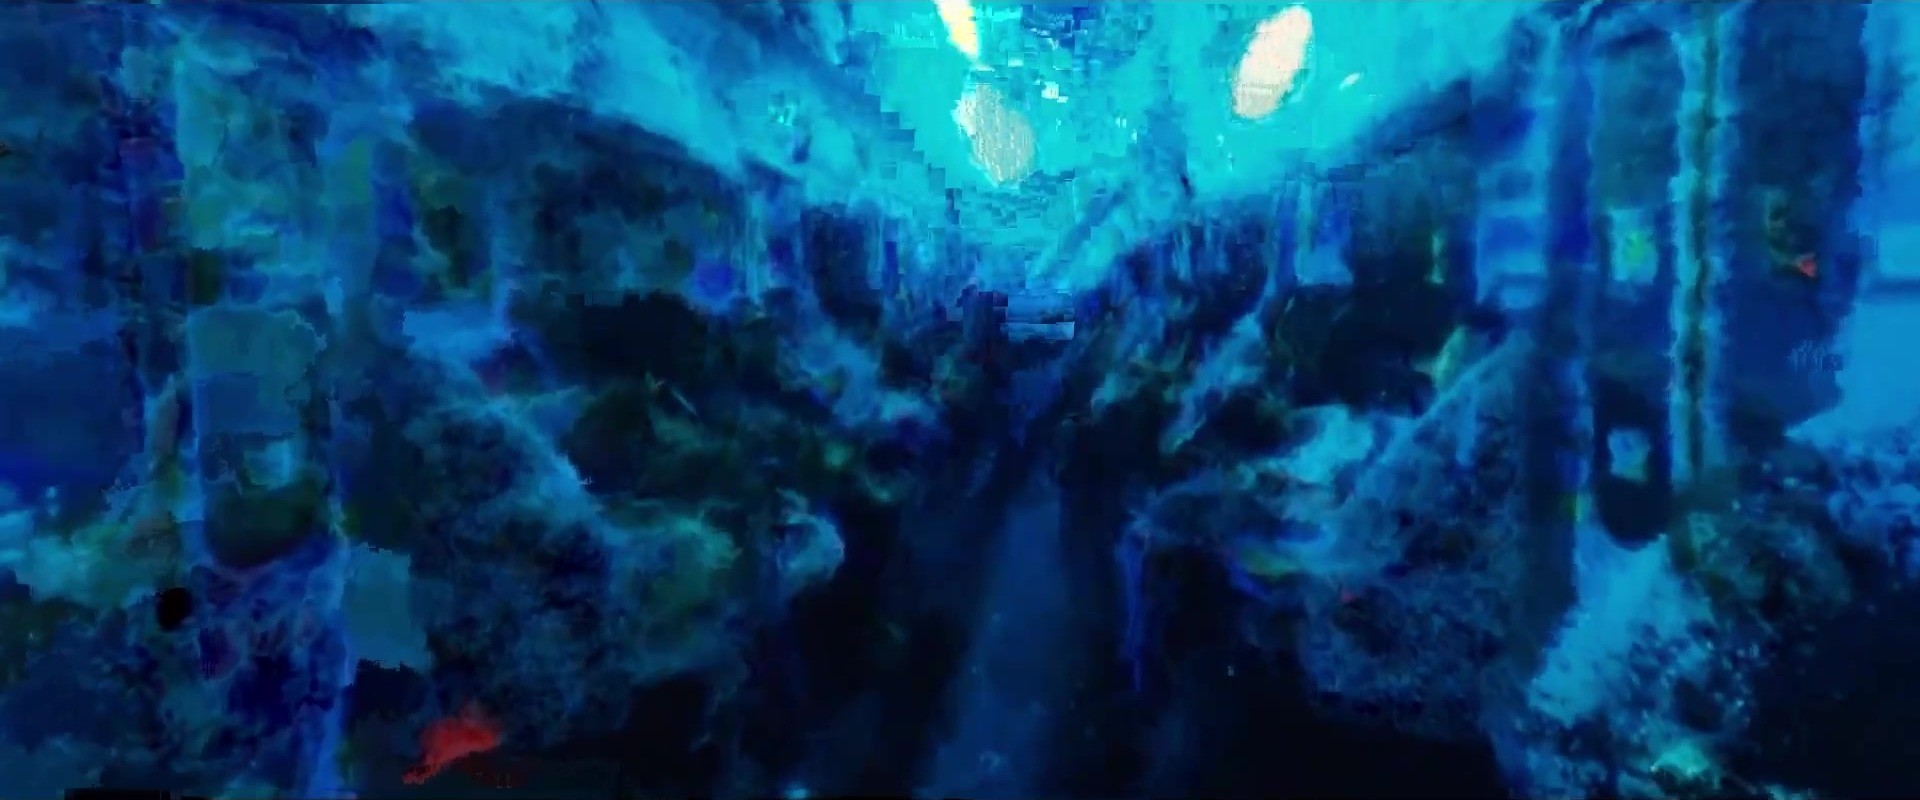
Dark Data: Surveillance
A point cloud study in surveillance and data capture
Surveillance capitalism is dissolving realities: it runs on the quiet collection of massive amounts of personal data, poured into data lakes far larger than any one person can picture.
Dark Data tries to make that collection visible and physical. Instead of a chart or a headline number, it visualizes the idea with point clouds: LiDAR scans recorded in real time on an iPhone, where a room, a hallway, or a person becomes a dense field of individual data points rather than a photograph.
Each point in the cloud stands in for a fragment of captured information. Together they form something that looks solid from a distance and comes apart, point by point, up close, the same way "dark data" (collected and stored but never quite seen by the people it describes) is technically present and functionally invisible.
Capture, track, dissolve
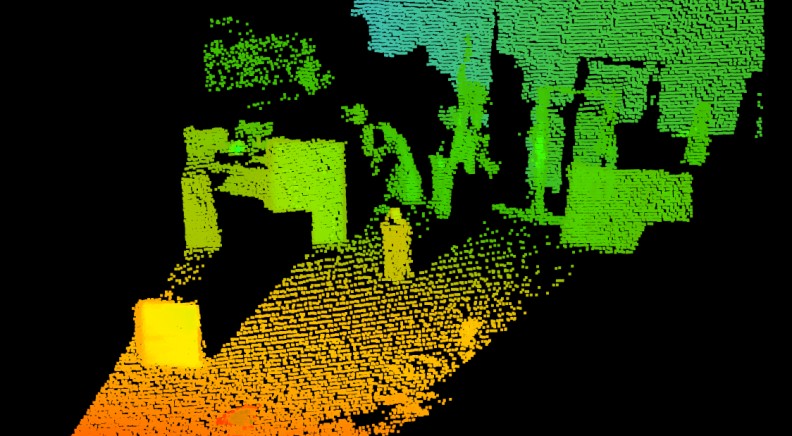
The piece runs on a three-stage real-time pipeline built in TouchDesigner: a LiDAR capture becomes the raw geometry, OpenPTrack turns that geometry into something aware of the bodies moving through it, and a particle system pulls the tracked cloud apart into the drifting fields that give the piece its name.
Scan the space
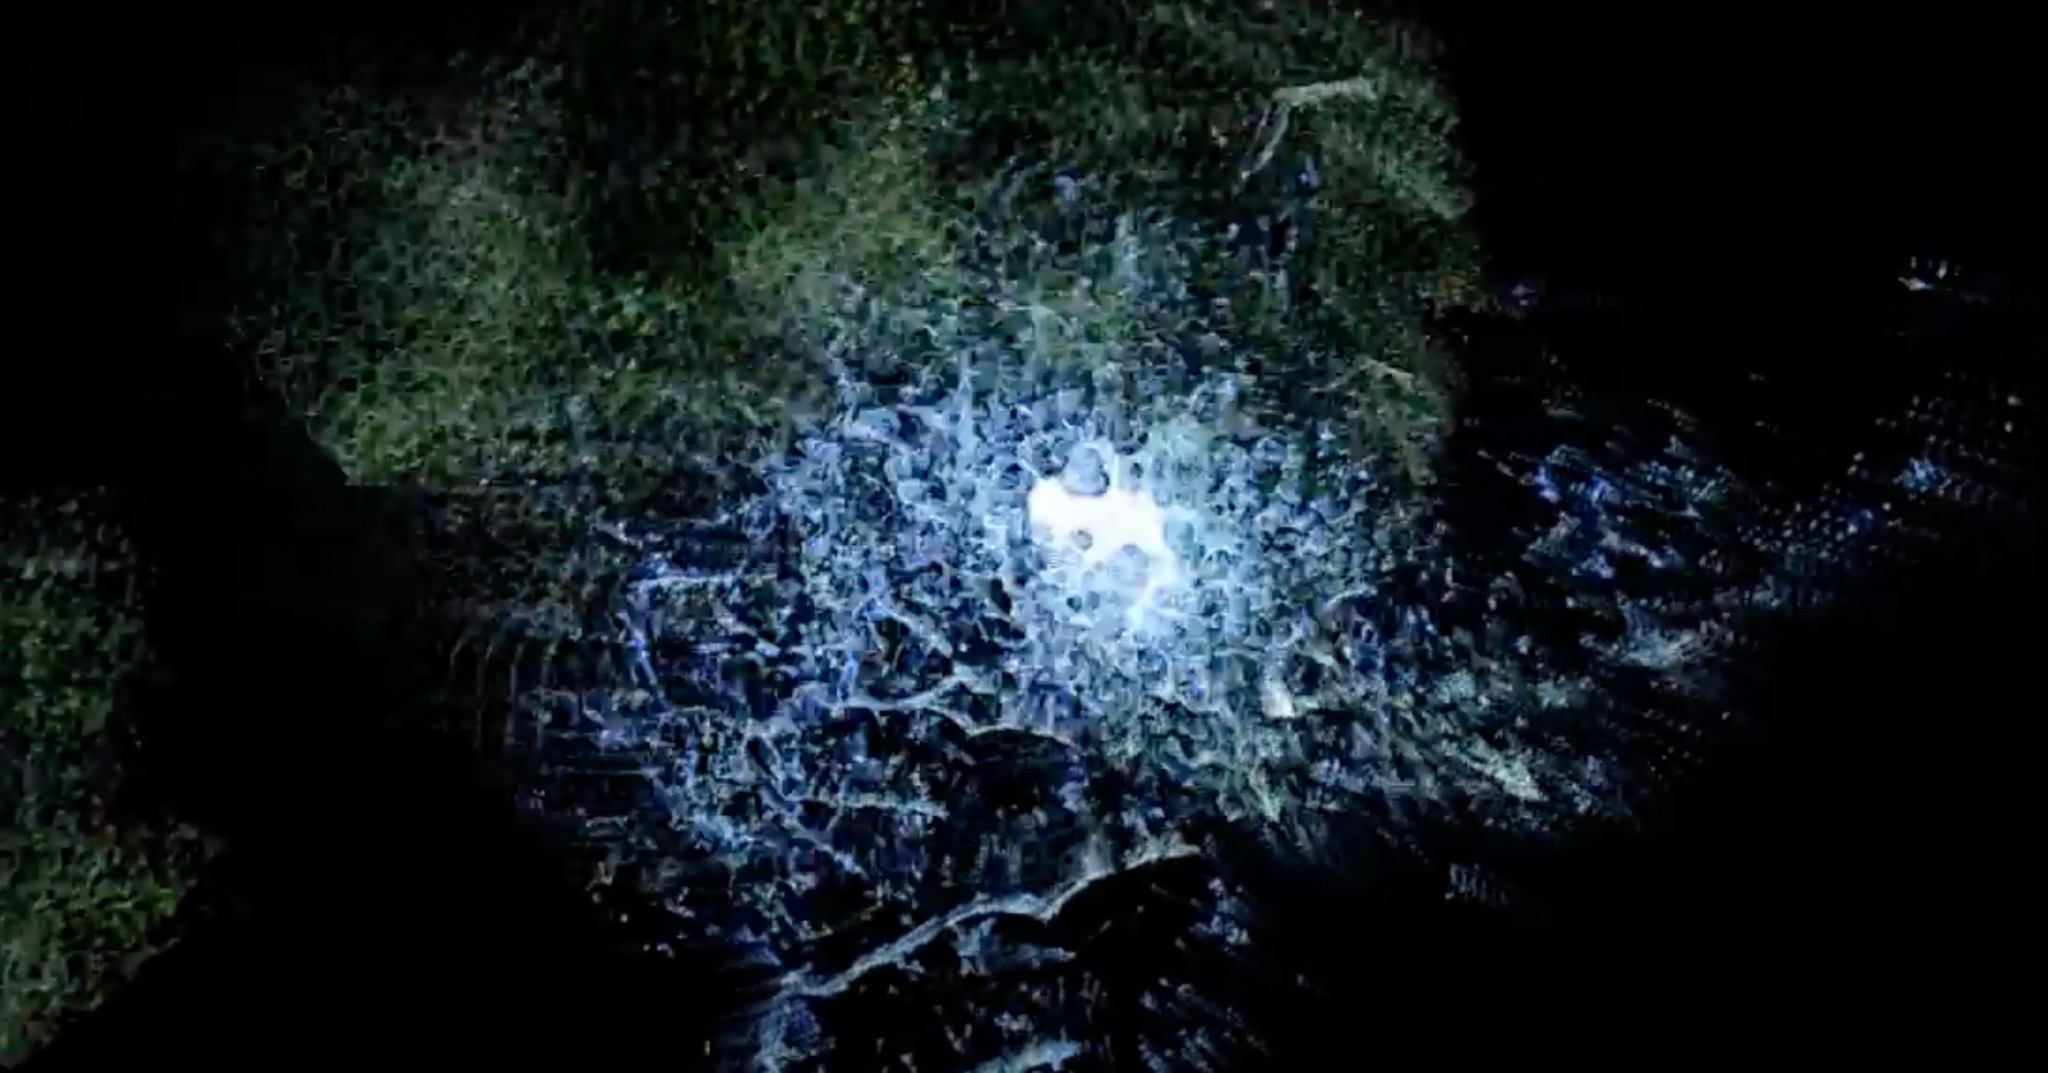
An iPhone's LiDAR sensor records a live depth scan of a real environment (a tree-lined path, in this pass), returning a raw point cloud instead of a flat image. Every point carries a real position in space, not just a color.
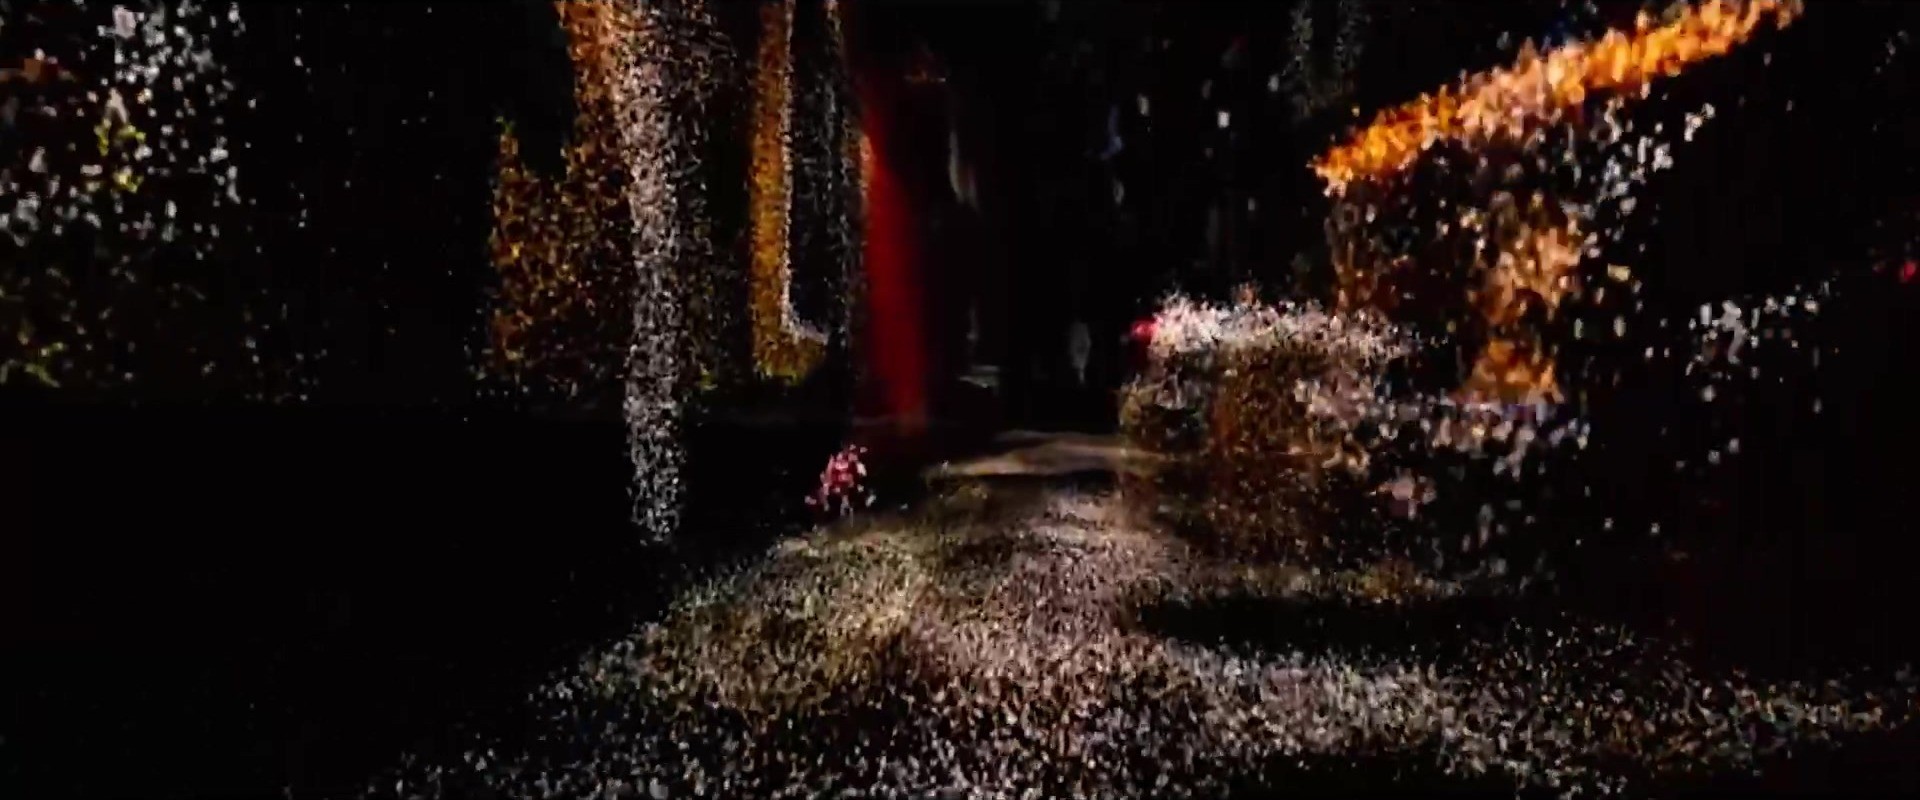
Follow what moves
Inside TouchDesigner, OpenPTrack tracks objects and people moving through the scanned space in real time, isolating a moving body from the static geometry around it: the moment the piece stops being a scan of a place and starts being a record of who passed through it.
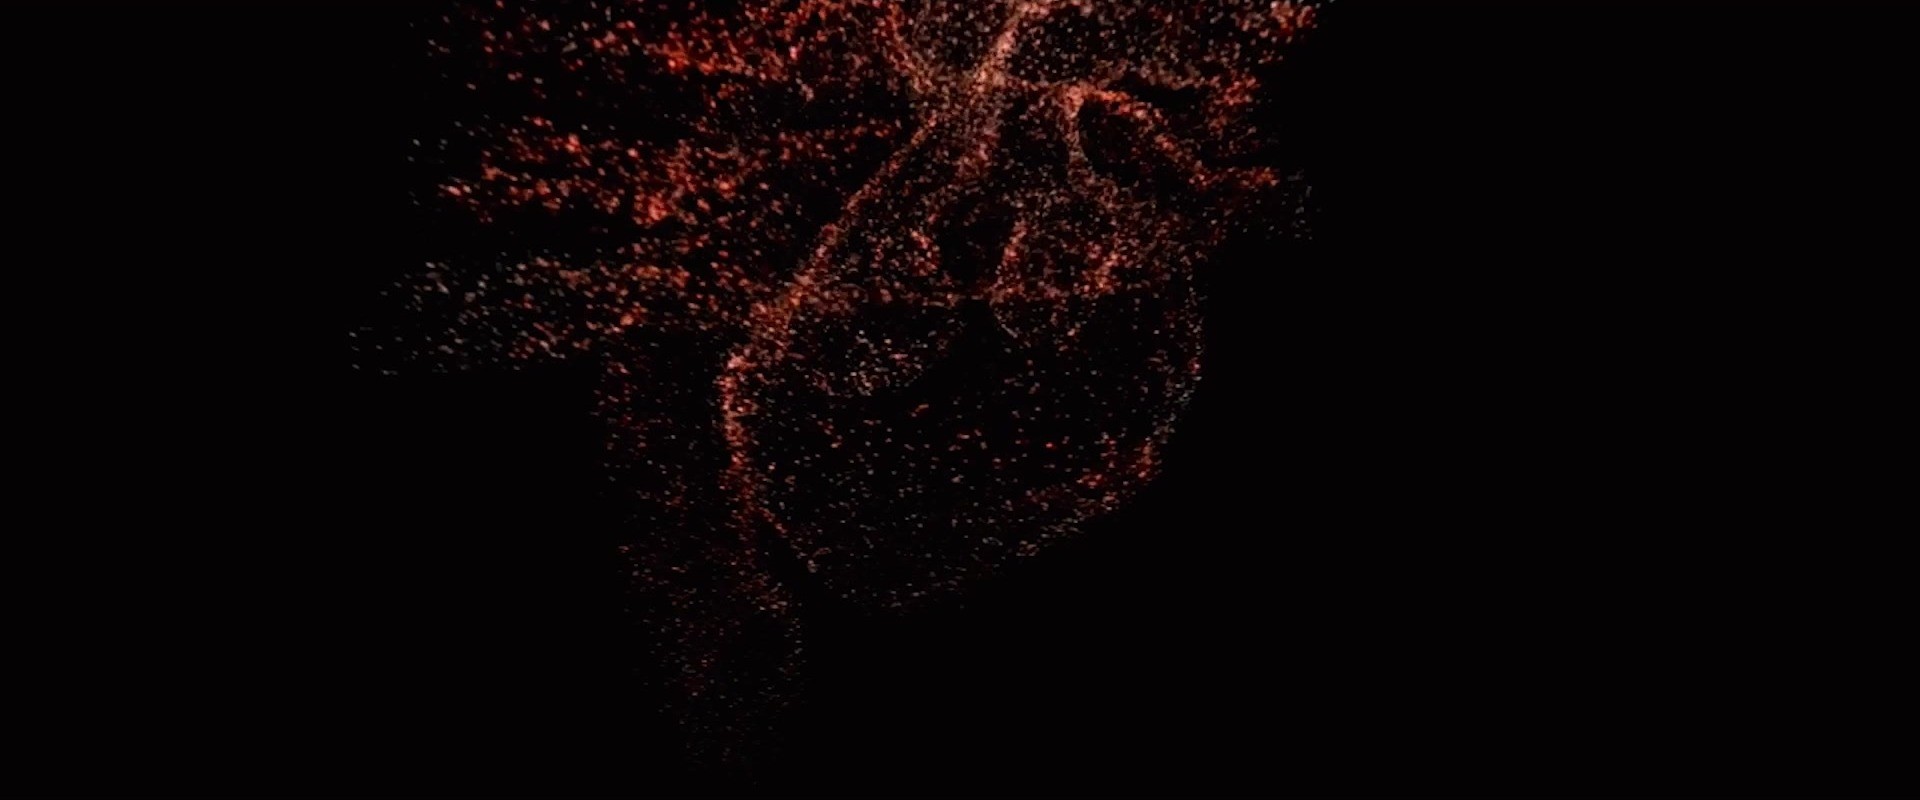
Break it apart
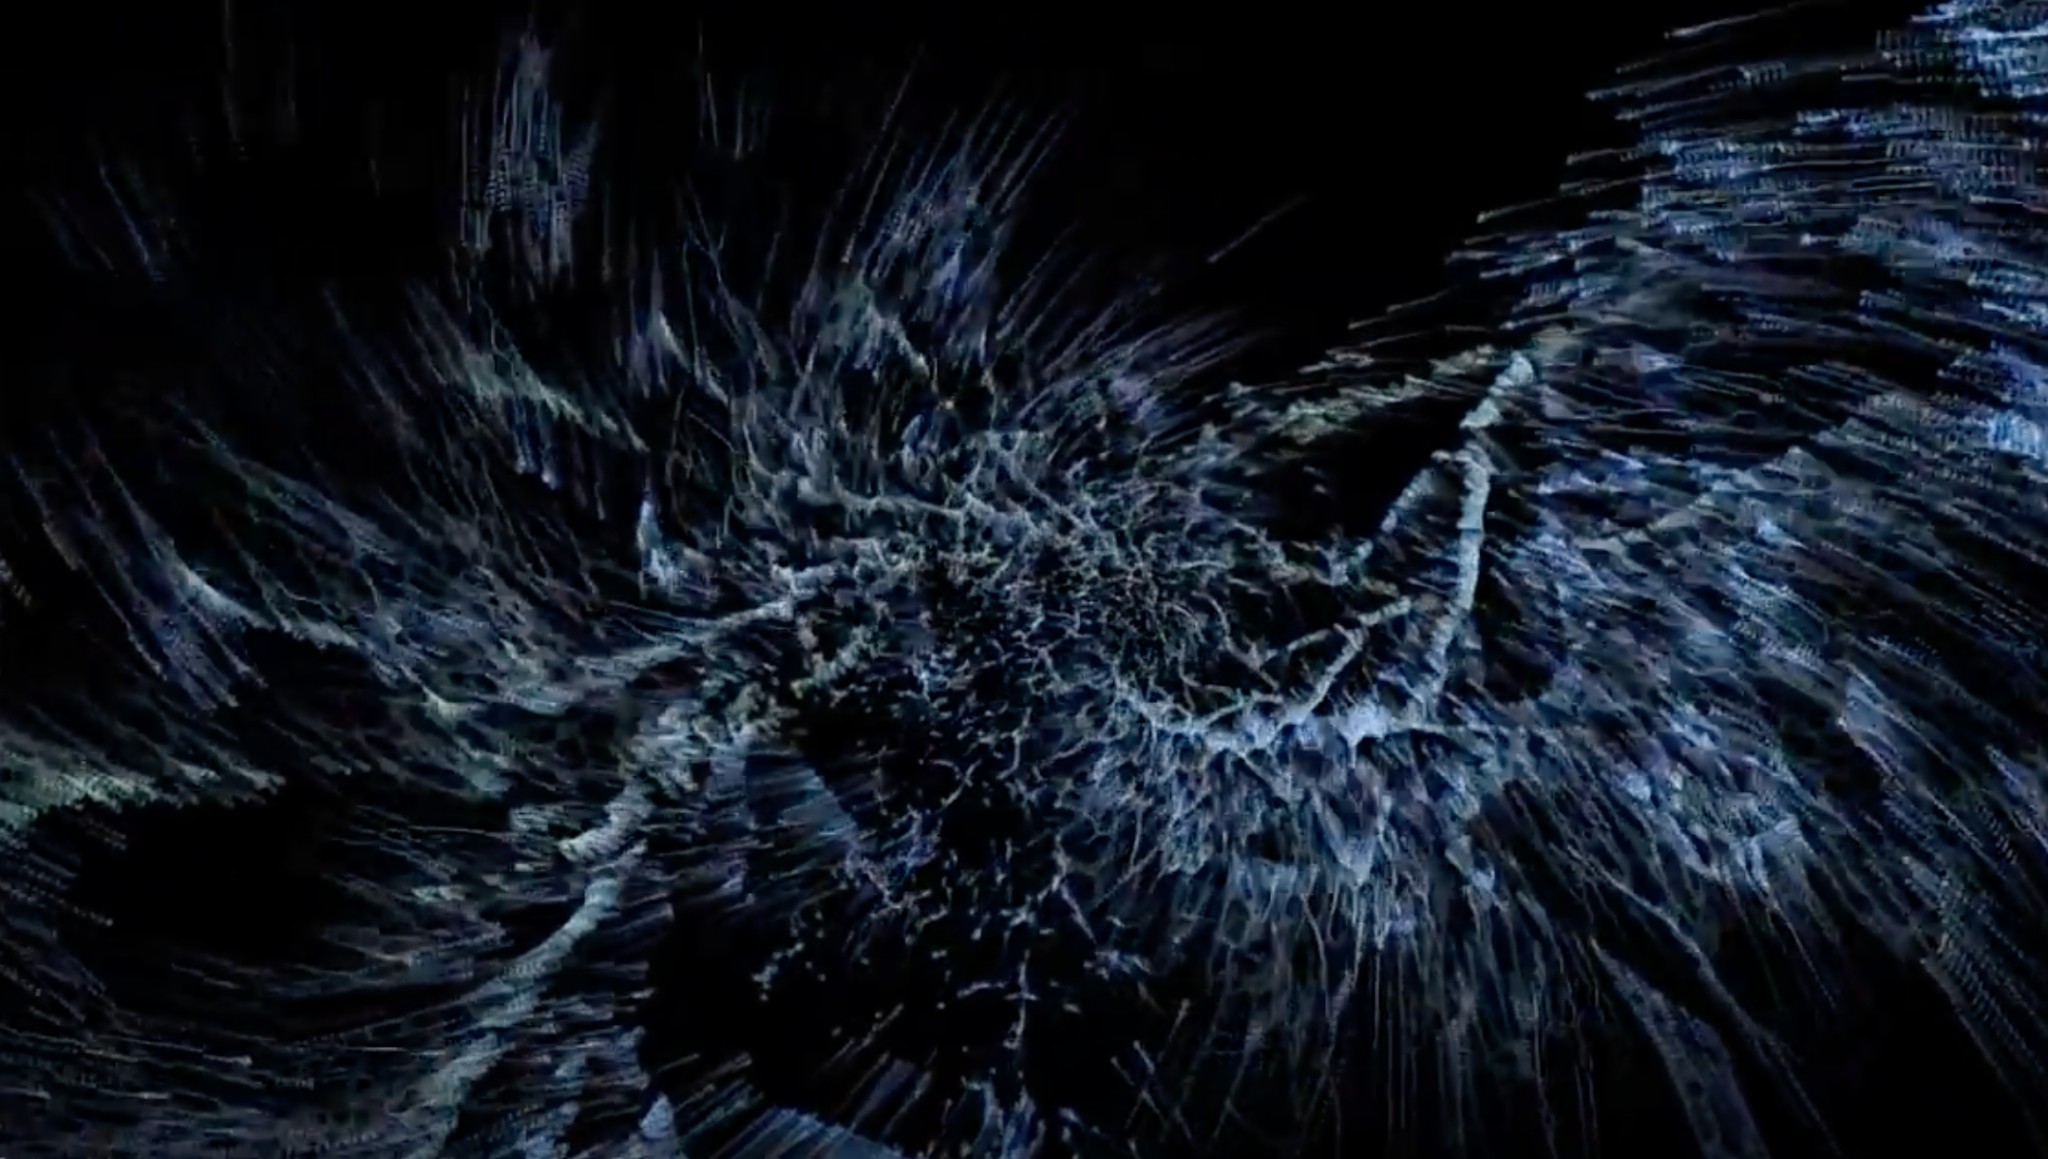
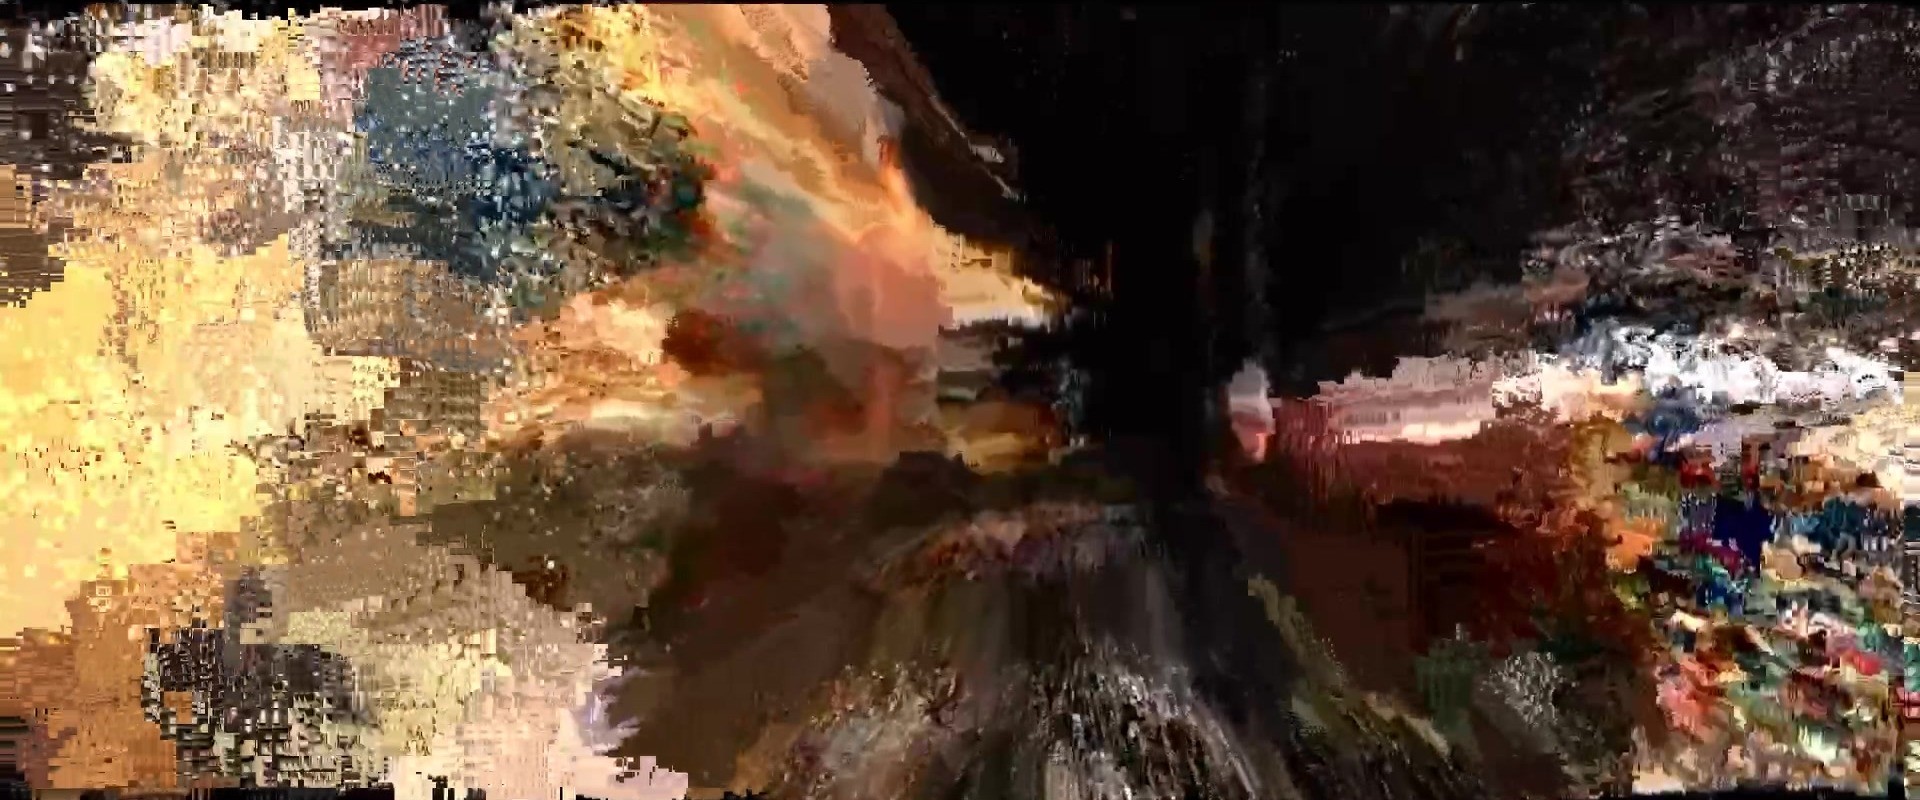
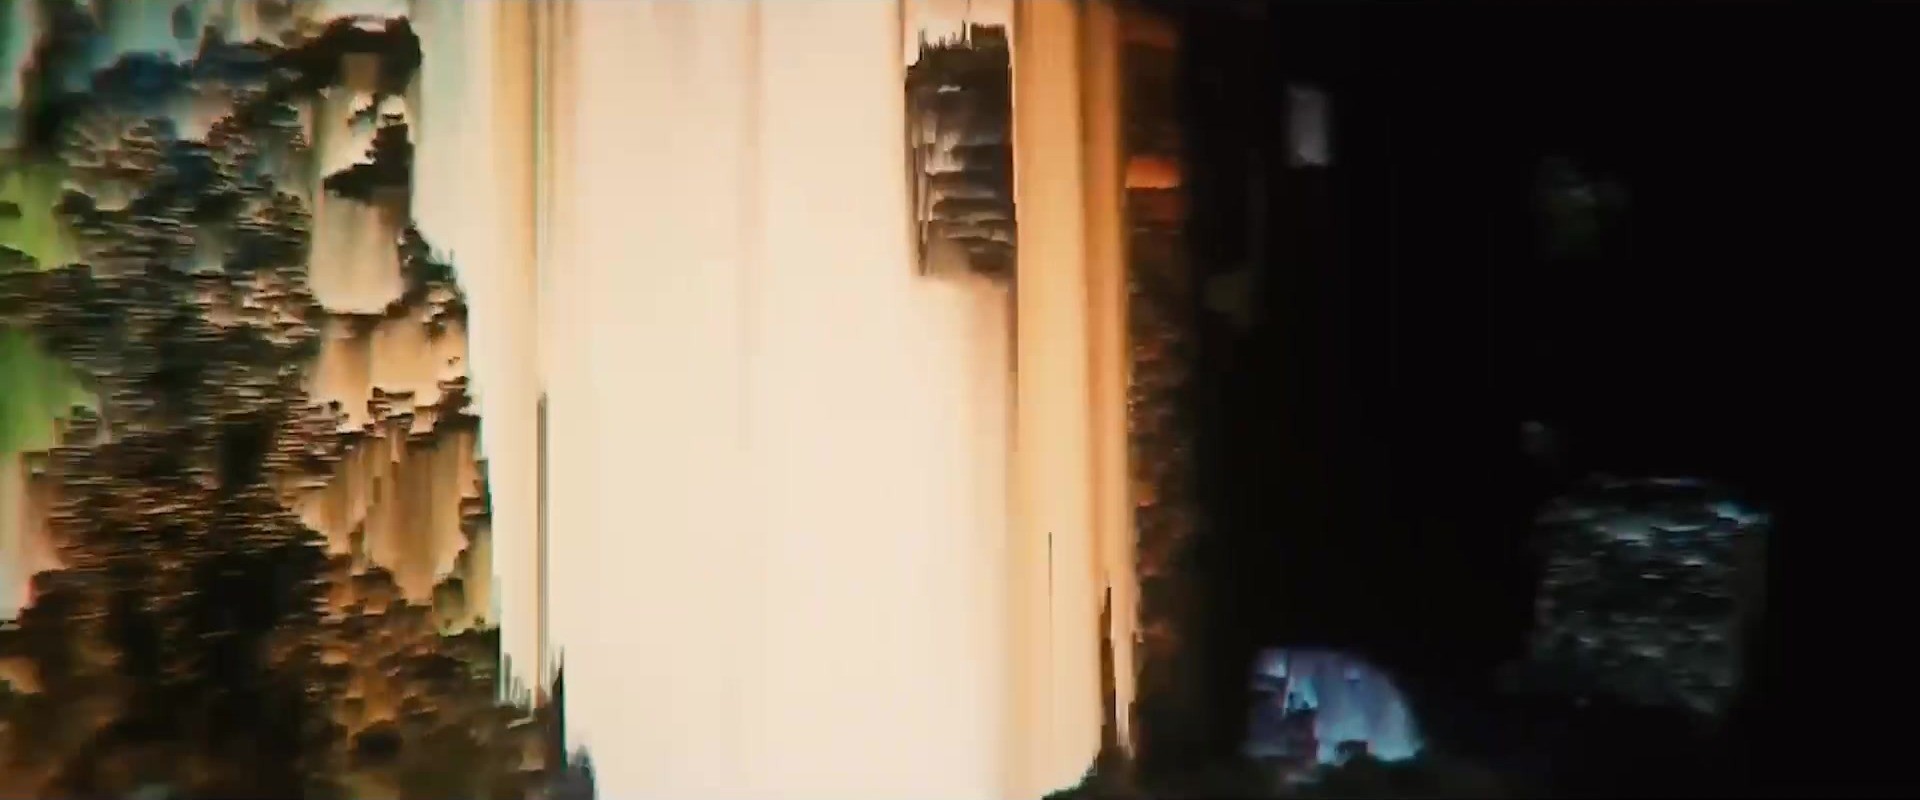
The tracked cloud is pushed through a real-time particle system, breaking the clean scan into drifting, unstable fields of color. The recognizable scene is still in there, but it no longer holds together as one solid thing, the same slippage the piece names in its title.
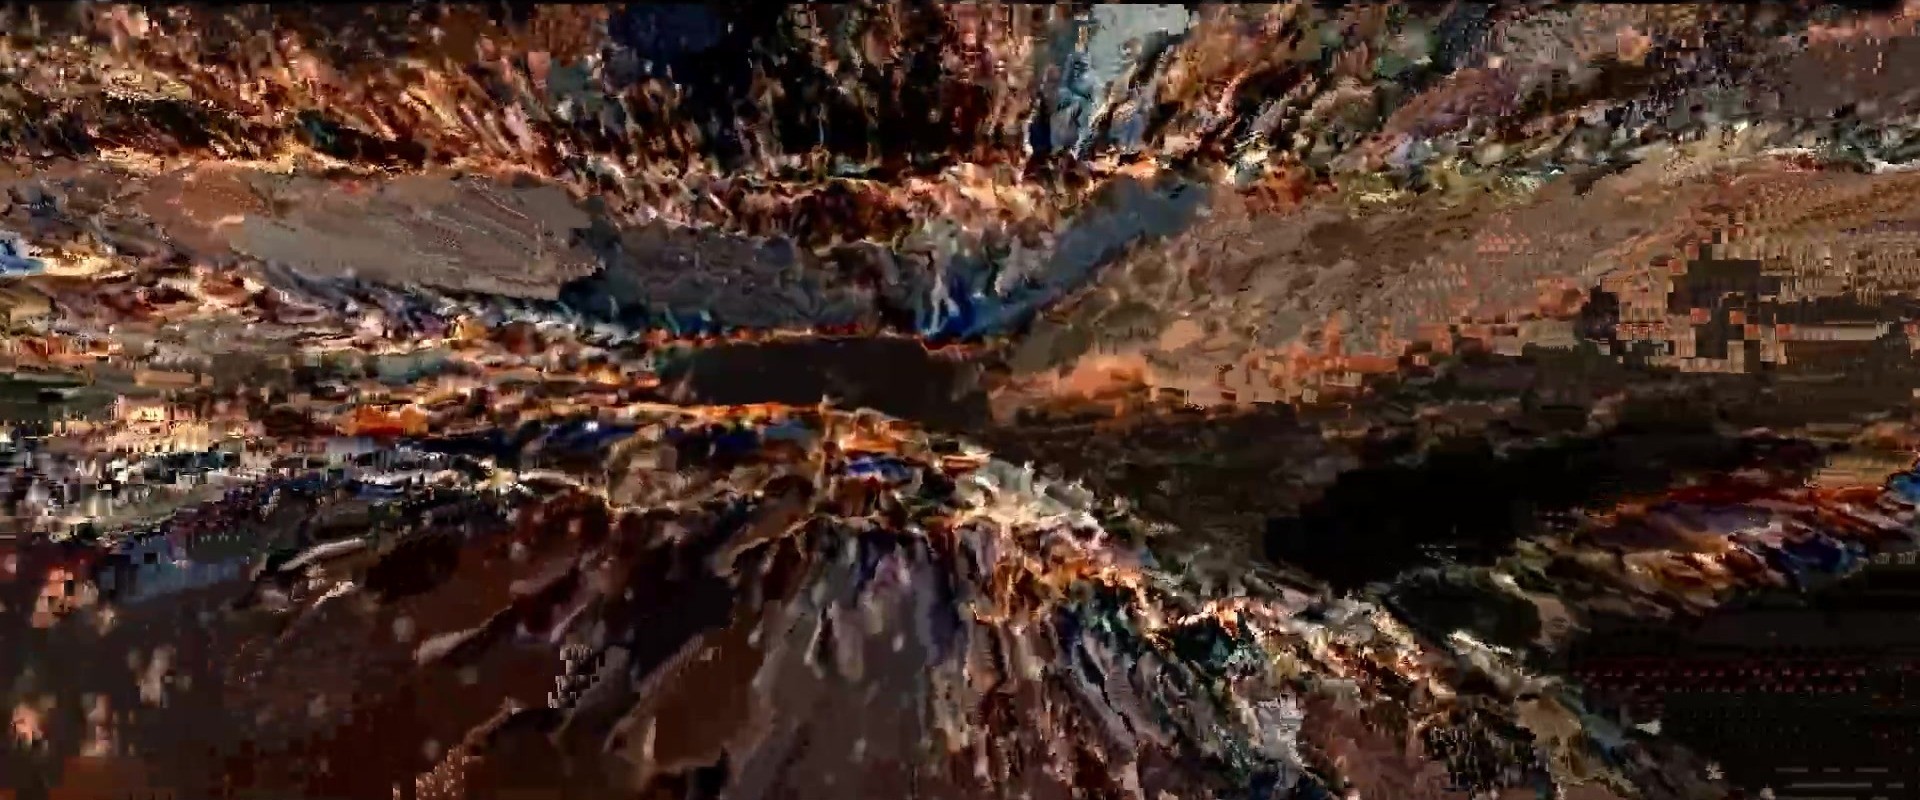
Capture log excerpt
The finished animation runs 45–60 seconds on loop. This clip is an excerpt from the longer real-time TouchDesigner session it was captured in, moving through all three stages above.
Selected frames
Stills pulled from the same capture session, each a single frame of the point cloud mid-render rather than a composited image.
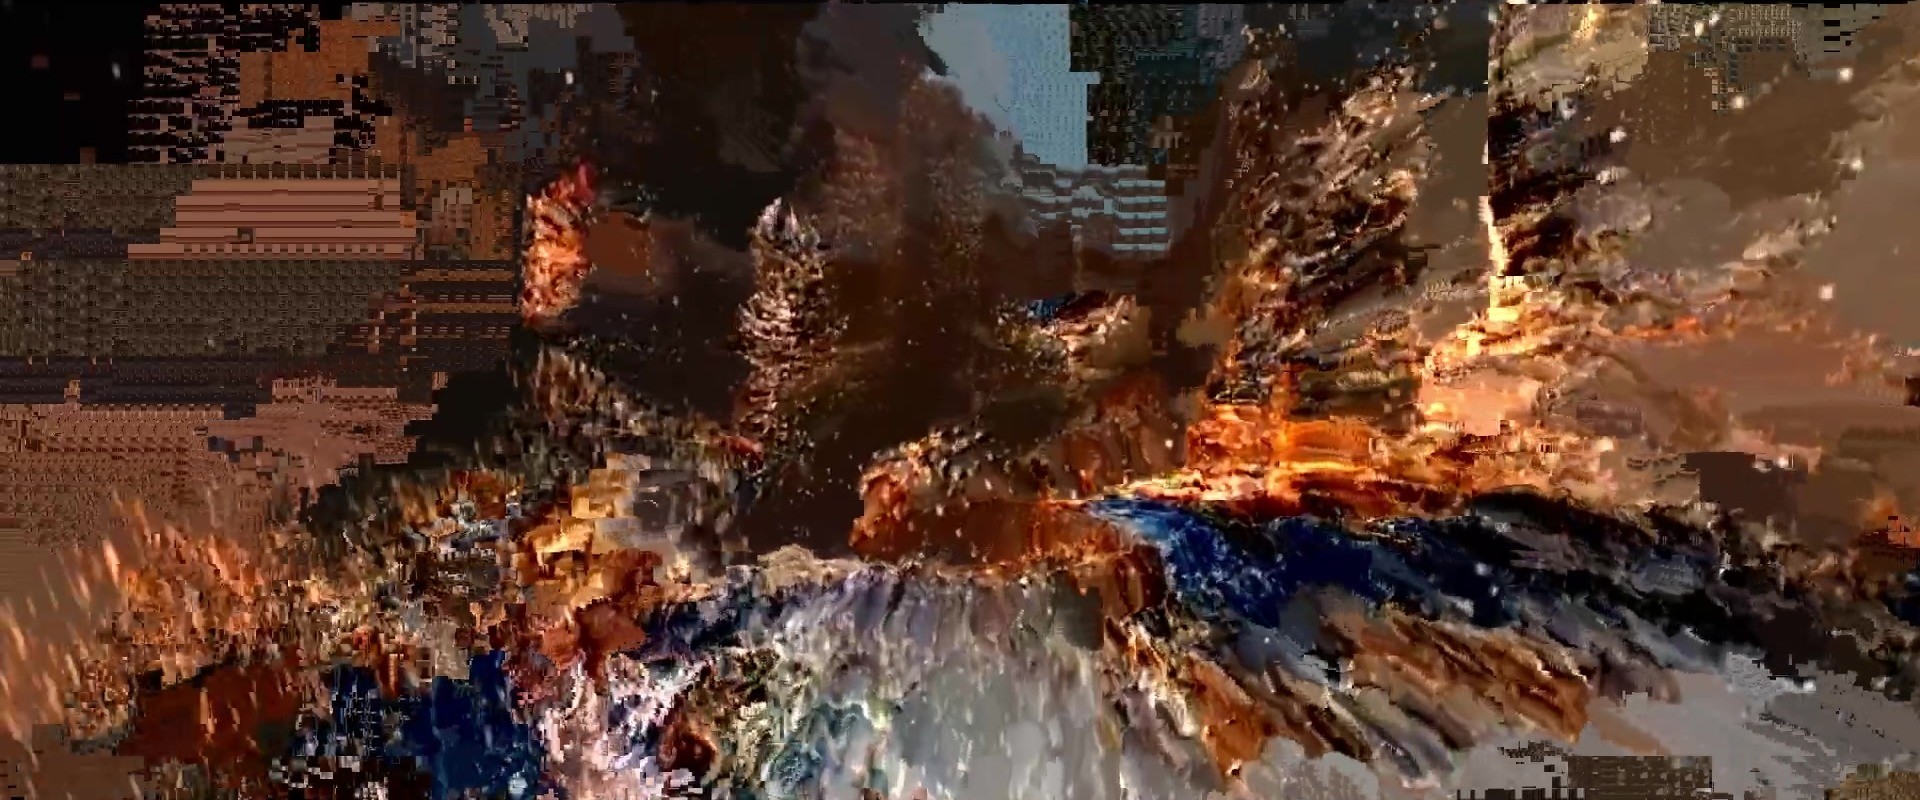
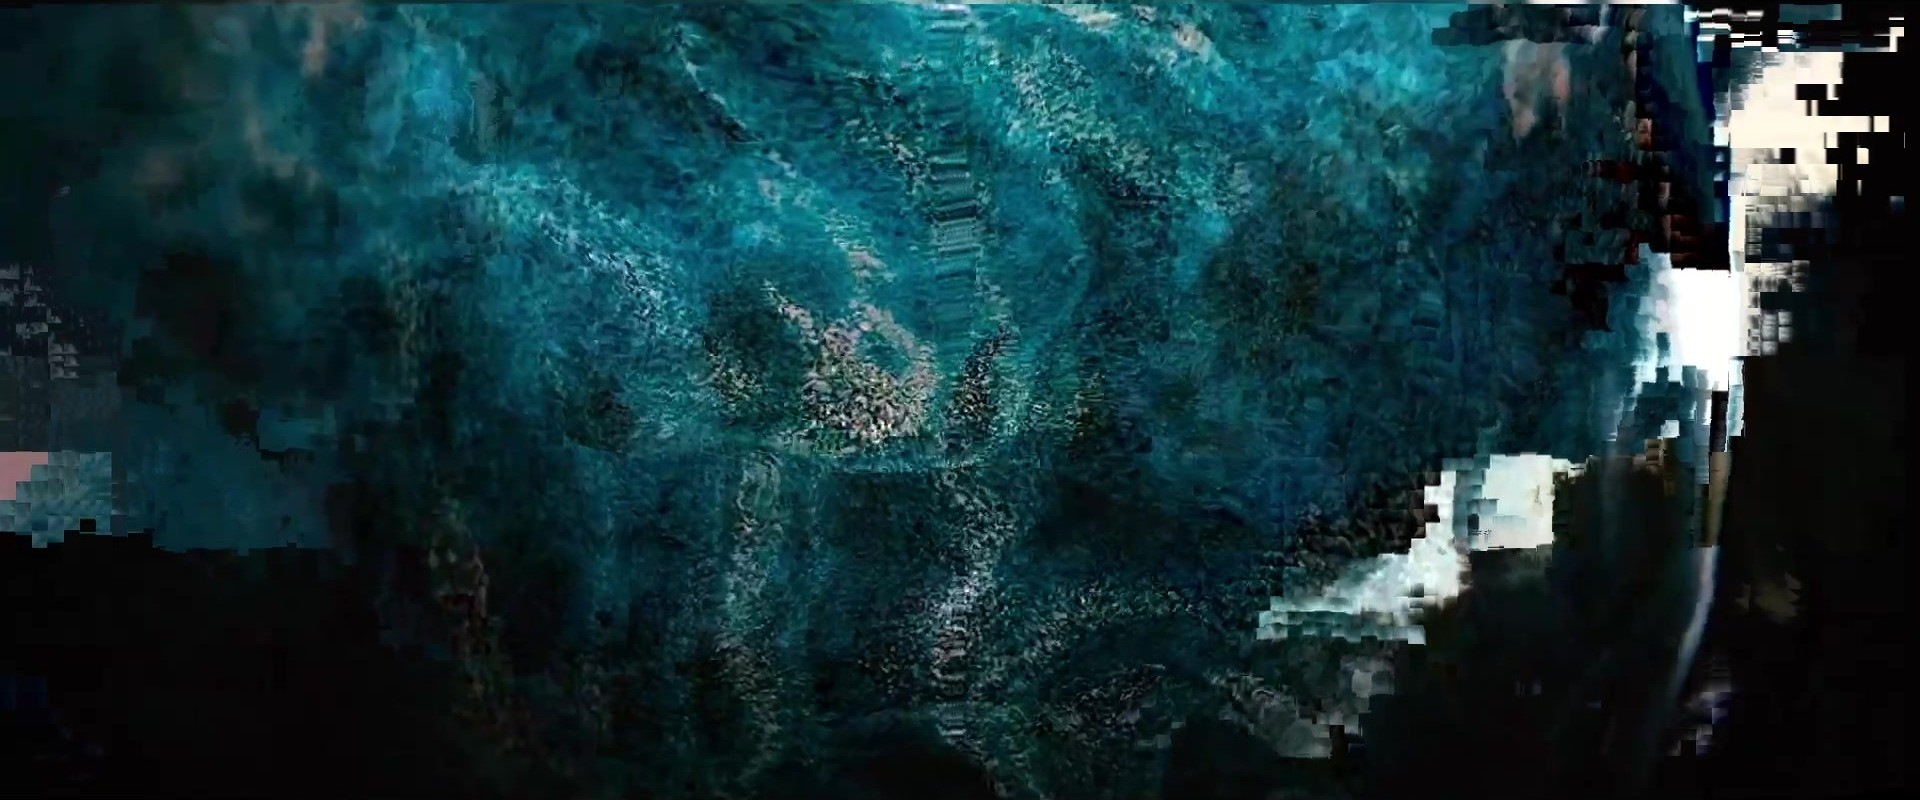
"Dark data" isn't hidden. It's collected, stored, and mostly ignored: present in every data lake, unreadable to almost everyone it describes.